Wednesday, 10 April 2013

Taking Stock

I've now decided on all the specific parts of the drone.  A big thank you to the eCalcs website in helping me with all the calculations!

So the decision:

Motors: 
High torque is good for efficiency.  I learn electric motors are measured in turns per volt, so a nice low kv motor will be fine :)  This is complicated only by the number of manufacturers out there! The good side is healthy competition so these great motors are not too expensive!

It's a bit "suck it and see" however the eCalc website tells me the Turnigy Park450 motor is good.  It's on the higher price side $16.45, that's OK as I'd rather have a good flight time and reliable motor!

Battery:
Here's the compromise already.  In a previous post I'd decided the battery.  On reflection I think two 5000mAh batteries are too heavy, so then I looked at 4000mAh.  Great, I looked at my lovely spreadsheet and found the right battery, wrong.  The 4000mAh battery was out of stock as was the 5000mAh battery :(

The compromise, I've gone for two Zippy 3700mAh batteries.  What does that mean?  Roughly 1.5 mins less flight time.  Never mind, at least I'll have the batteries soon for development rather than waiting.
One thing to note, the Zippy brand from Hobbyking are the lowest quality so will give up at around 100 charges ... but they are the lightest!

Electronic Speed Control
These control the motors from my Gadgeteer board.  It needs to respond quickly to powering up the motors, with a low internal resistance to save power and avoid overheating.

I've chosen the Hobbyking Blue Series 20A, motors go up to 14A.  Why this model?  It's meant to be a fast responding ESC and light weight.  We'll see.  It's on the higher price side at $10.37 however this might just keep the drone from crashing!


Propellers 
Easy one.  The eCalcs says for my drones weight with the particular motor I'll have that 10" propellers are best.  Ideally I'd like black propellers however they were out of stock, lovely bright green ones instead.  I'm sure I'll get used to it!

Wednesday, 3 April 2013

Airframe Arrived!

Oh yes yes yes!!!

The airframe for the drone arrived yesterday!  I'm so excited to assemble it.  

Sadly I have a few late evening for work and I'm away at the weekend.  With a bit of luck on Sunday evening I'll start assembling it :)

Below are some lovely pictures of what I have to play with :)

Arms
The drone has 25cm arms, it will have four arms plus four spares just in case any crash damage!

Landing "Gear"

Center Hub
The center hub of the drone which the arms attach too!

Monday, 1 April 2013

Captain: Signal the Motors

How to get the Gadgeteer signals to the ESC to control the motors?
The ESCs need Pulse Width Modulated (PWM) signals to then control the motors.  PWM is relatively easy to understand and there's a great webpage on Wikipedia.

The Gadgeteer board I have gives outputs PMW signals so life is good :)  Apart from the usual problem, not enough ports on the Gadgeteer board!

Along comes my friend!  Pulse InOut from GHI Electronics.
What's lovely about this board is that it can support eight input and output PWM signals!  

I only need the four output PWM signals however I'm thinking perhaps the inputs could be used for ultra-sonic sensors to help automated landing and/or obstacle avoidance.  That'll be for later on in the project :)


Wonderfully, the Pulse InOut board indepently generates it's own PMW signals from a command rather than forwarding on a signal from the Gadgeteer board.  Why is that cool?  

If the code on the Gadgeteer board hangs then the motors still get their signals!!!  I love this fail safe(ish)  approach!!!

Safe Landing
Perhaps I might (later on) code for the chip in the Pulse InOut board for the case if the Gadgeteer board code does hang.  

I'm thinking along the lines if the Pulse InOut does not receive any PWM commands from  the mainboard for say 10 seconds then it gives equal power to the motors to hover and then slight decrease in power to enable landing.

Buying Time
I can't wait to get the board and start coding for it!  I placed the order with Proto-Pic a few days ago and being Easter there will be a few extra days wait.  Hopefully it'll be here before the weekend!  Yea!!!

Sunday, 31 March 2013

Best Battery!!!

I love maths ... some calculations have just more than halved the battery cost for the same performance, enjoy the post :)

I ask myself, which battery has best capacity to weight ratio?  Out comes the spreadsheet!


I went through all the 3 Cell batteries on the Hobbyking website, found the lightest for each mAmp and divided by the weight to give mAmps per gram.

The Comparison 

There a big difference between the best and worst batteries!  The best battery when compared to worst battery is 34% better, like for like that gives an extra two minutes of hovering flight.

FYI, interesting the best overall battery is in the model speed boat section.

Ultimately I'm looking at time in the air.  So what about the 6100mAh battery? It's has a worse mAh/g however it holds a third more power.

According to the eCalc website site, it estimates the best 4500 mAh battery 17.4 mins in the air where the 6100mAh battery gives 19.4 mins in the air!!!

Do we have a winner?  I thought so except a school boy error ... I forgot the cost!!!

The Cost of Power

6100mAh battery is $100 USD and the 4500mAh battery is $58 USD.  Both are a lot for a battery!

Perhaps one day I'll buy these batteries however I want to constrain the costs.  The 5500 mAh battery $96 however the 5000 mAh battery is $27 USD.  Much more like it!

My Winner

I think we have a winner!!!  It gives me more air time at 17.6 mins and half the cost of the "best" specification battery.


More interestingly this battery is light enough to parallel which that gives 24 mins of hover time with thrust left over for maneuverability.

Friday, 29 March 2013

Battery Investigation

What an amazing website this one is: eCalc

It is fantastic, all the aeronautic calculations for you!!!  It's been a big help and homed my design ... I'll write a bit more about it on another post :)

Batteries!  What to choose from?  I know I need a 3 cell battery for the right voltage yet with hundreds of 3S battery it's difficult to decide.

Lots of people on their quadcopters are using 2100 or 2500mAh.  Yes why not use that! :)

Oh dear, on the calculation website only 10 mins of hover time and about 6 mins of high powered flight :(

I need time in the air, therefore a big battery.  What's the largest 3 Cell battery on Hobbyking?  How's about a nice big 8400 mAh?


It's a beast of a battery at 640 grams yet that gives me about 21 mins of both fancy high powered flight and hovering.

One thing that was bothering me was the heavier the battery the more power needed to make the drone hover.  The more power need to keep it in the air the less we have for accelerating forward and maneuverability

Ummm, we could have a drone with a long hovering time yet not able to keep up with me.  Ummmm.

I was thinking, is this the best battery?  

The above battery is the lightest 8400mAh for that capacity and is the best (on Hobbyking) battery in terms of mAh per gram.  Are there batteries with less capacity with a better mAh per gram?  

Then I starting thinking, if I optimise the mAh per gram then this reduces the weight and we have more flying time :)  Yea!!!

Then I remembered my basic physics, I find the best mAh per gram battery and then put them in parallel !!  could then have the correct voltage and lots of power!!!  Why not 10000mAh?  Yes, this could be excellent!!!  

Time to create a spreadsheet to find out :)

Tuesday, 26 March 2013

I've Been Framed

I've been doing some basic calculations on power, weight, etc. and I released that it is time pin my flag to the mask to choose an airframe :)

Weight is critical on a hovering aircraft so let's go for a light one ... to be exact, the lightest and strongest my pocket will afford!

I've seen some airframes ... some amazing carbon fiber ones at a lovely high price, some very good looking ones however out of fiber glass or worse.  With the amount of crashing that's bound to happen, I think I'll need something stronger than fiber glass and ply wood.


So what have I chosen?  A while back I was really taken with Warthox videos ... this is amazing Quadcopter video.

It's just fantastic!  There is the option of carbon fiber however, as I'm starting out, aluminium is best.

So I've placed my order! I'm going via Flyduino and those guys are great, I placed the order yesterday evening and shipping today!

I'm so looking forward to starting to see something more physical in addition to the electronics.

Time to chose the motors, batteries and ECS :)

Saturday, 16 March 2013

Power to the People

I've been getting a bit side tracked with all the sensor issues.  Time to learn about batteries :)

Lithium Polymer, LiPo, is where it's at ... better than Nickel Metal Hydride yet cheaper than Lithium Ion.

There's a huge range of batteries from Hobbyist websites, so let's investigate what I need:

  • Light weight ... postman will love me however it's for the drone's benefit
  • Large energy capacity ... fly forever!
  • Small size
  • Cheap ... not cost me a fortune :)
I want everything!  I can't have everything :)

Something I've learned is the important of the battery "C Rating".  It stands for also how quickly you can safely drain the battery without damaging it.  Great little guide here!

What does that mean for me?

Four motors for me and lets say 20 Amps motors each = 80 Amps Continuous Discharge.  So I need a battery that will have a large capacity multiplied by"C Rating" = 80A continuous discharge.

Let's say the batteries I'm looking at have 2000mAh capacity, I therefore need it to have 80A / 2000mAh =  40 C Rating.

Voltage and Power

How much voltage do I need?  This relates to the type of motor I'm going to use!

Interesting, first to decide which are the right motors and then you'll know how much voltage you'll need.  Once you know that then you'll know which are the right batteries for you :)

So which motors?  Haha, that depends on how much power I need and that depends on the weight of the drone!

To add extra dimension, the more dynamic responsiveness I want the drone then the more instant power it'll need.  how dynamic I want the drone to move?  Plus also the money factor :)

Time to make an estimate of the drone weight!

Monday, 11 March 2013

Mainboard with chips?

Crazy weekend!  I was sweating at one point.

My lovely copy of Visual Studio Express hung during the deployment to the ArgonR1 mainboard.  Not to worry, reboot the computer and ArgonR1 and then deploy again.  Wrong.

The laptop wouldn't talk to the ArgonR1.  Was it fried?  Oh no!

I read on the forums it was best to re-flash the ArgonR1's firmware.  Great, downloaded the firmware and was ready to reset using Microsoft's MFDeploy.


Oh no, MFDeploy could not talk to the mainboard!  How then to recover?

All drivers deleted and re-installed, computer rebooted and still no joy!

Saturday blown, Sunday I was super worried.  Was the board dead?

I inspected the board just to see if there was something physically wrong with it ... that was the trick!!!

TOP TIP:  If your Gadgeteer Mainboard won't accept the deployment then do:

  1. Disconnect your Mainboard from it's power source
  2. Disconnect all modules ... except the computer power & communication module of course :)
  3. Power up the board and all will be good
Then board was the talking to MFDeploy, yea!  It was alive, I was very happy!  

With MFDeploy you can delete the current deployment, haha top idea!  Given there was some weird half deployment on the board that seemed a top idea :)

Then Visual Studio was as happy as me and was uploading programs to the ArgonR1 again :)

Excellent, I didn't have to re-flash the firmware or any other of those "risky" style operations, how fantastic.  

I love this little ArgonR1 board :)

Saturday, 9 March 2013

I2C Scratching my head

Back in the swing of the development after a time away and now scratching my head!

To recap, where am I ... sensors!!!!  Sensors are everything so the lovely drone knows what is happening.

The problem is that I need loads of sensors and not enough ports on my Gadgeteer board to connect them all.  The cunning plan is to network them together with the I2C protocol.


I'm having a big problem though :(

I just cannot get the a single sensor to talk to the Gadgeteer board!  


Not sure what to do next.

I've double checked the soldering, all good.  I've ensured the wiring is correct, all good.  Resistors on the I2C and Clock lines are good.  The C# code module code is super simple and no joy.

I think I'll have to buy an I2C Gadgeteer component just to check the module code is correct.

Saturday, 16 February 2013

Soldering fun

Finally back from my travels and back into the Drone :)


The Gadgeteer Prototyping board from Love Electronics allows a connection from the Gadgeteer main board into your own electronics.  You have to create your own Gadgeteer model however that looks relatively simple.  Fantastic!  

I have the sensors boards which I'll breadboard into the Prototype board for flexibility. I'm going to first try creating a Gadgeteer Gyroscopic sensor module :)

So I have my lovely sensor board from Love Electronics, time to solder some pins to it.  It's been quite a while since I've soldered however once back in the swing it was OK ... ish :)

Top tip for anyone, get the right end for your soldering iron!!!  


The original one was a chisel type which I discovered was too thick, then I tried a pin point one.  Much better, although it took far too long to transfer heat into the solder.

So I tried to solder the pins to the board, it was OK.


Not the best soldering however it was all electrically OK.  Yes now the pins are on the board!

Now to get the sensor onto a breadboard and hook it up on the Gadgeteer prototyping board.

I thought I'd tried another tip for the soldering iron.  Yes a thin chisel was the best :)

The jumper strip had to be soldered onto the prototype board and that was a dream with the new thin chisel.


End result: I now have my electronics for my Gadgeteer sensor.  Time to write the module software :)

Friday, 8 February 2013

Not much yet

Sadly not much drone work for a while as I've been away from home on work for while :(

Still, looking forward to getting back tomorrow and cracking on with my lovely soldering iron, yea!!!

In the meantime, very interesting video here on controlling quadcopters ... excellent!

Wednesday, 30 January 2013

Daisy, Daisy ... give me your answer do!

One of the problems concerning me was, I have many sensors and not enough connectors on the Gadgeteer Mainboard ... what am I do to?

I'd seen that the Gadgeteer board has I2C (pronounced "I Squared C") and oddly years and years (11 to be exact) I'd done some I2C development.  Basically it allows a master controller to talk up to 126 components.

Fantastic!!!  The question is how to connect I2C breakout boards to a Gadgeteer main board?  Thankfully the book Gadgeteer book I've been reading has all the information :)

Here's the plan, I'm doing to create my own Gadgeteer module.  Physically it will have three senors on it that are all connected via I2C.  I'll then write the module software so the Mainboard can connect to all three via the I2C.

Sounds hard however the module software is easy looking.  The tricky part will be the initial configuration of the sensors however once that is cracked it's happy days :)

Best of all, I can create my own modules that link to further modules.  Gadgeteer calls this "DaisyLink" which seems to be an implementation of I2C for talking to multiple devices thus removing some of the complication for me.  Great one Microsoft :)

First step, create my module ... I'll do something simple, not sure what yet :)

Sunday, 27 January 2013

Reading Time!

It was a lovely family weekend, so no drone development.

However, I did have time to read a book, "Microsoft .NET Gadgeteer: Electronics Projects for Hobbyists and Inventors"

It's been about 3 years since I've coded, it's nice to have a quick refresher plus learn a few new tricks for Gadgeteer and the .NET Micro framework.

I'm half way through and definitely can recommend the book to anyone new to low powered processor programming :)

Saturday, 26 January 2013

First Gadgeteer Program

I should have gone to bed, I was too excited to create my first Gadgeteer Program on the Argon R1 board ... here's the result :)

Thursday, 24 January 2013

Yea, electronics arrive!!!

Woop woop, the electronics are here!!!  That Argon R1 is a thing of beauty :)


Time to start learning :)

Also, Love Electronics have been a top company.

Communications has been fantastic!!!  Answering questions, keeping me informed on the delivery and being genuinely nice all round.

A pleasure buying from them! 

Wednesday, 23 January 2013

Time to lock down the design?

Time to take stock!!!

Lots of learning over the last 5 days.  There's a lot in my head right now, many thoughts about the pilot control of the drone ... must write that down.

The electronics coming which will be fun, there's more learning there!  Last part of the puzzle is connecting the Electronic Speed Control (ESC) to the Gadgeteer Mainboard.  Definitely do-able, so I'm not worried.

Once that is done, time to lock down the design.  I can't believe in 5 days this has gone from impossible to possible.

What's Needed in an Airframe?


Here's a few things I reckon I need ... will be fun to look back in a month and see how it has changed!

  • Lightweight ... I can't afford Carbon Fibre so Aluminium looks good
  • Strong ... one I don't want it to break on the first go!
  • Structural Integrity -  I want to minimise vibrations ... that will do the sensors no good.
  • Storage ... somewhere to hold the electronics, batteries and camera

Sounds a tall order ... time for more research!

I reckon the Motors and ESCs now not hard to decide on after yesterday!

The final electronics are tricky to decide.  I have a theoretical idea on how many sensors are needed however that all depends on how the real machine flies.  Let's just have some fun :)

Gyroscope Arrived

First package from Love Electronics has arrived.

I'm now the happy owner of a 3-Axis Gyroscope and super looking forward to Love Electronic's Argon R1 arriving sometime tomorrow!

Tuesday, 22 January 2013

Mystery solved ... Airframe, Motors and Control!!

Oh how fantastic!!!!  I knew I was missing something!!!

I came across this top website where it lists components that other's use, excellent!

Also there's links to other hobbyists who on their webpages list the parts they use ... I am so lucky, I love the internet age!  FYI, here's one hobbyist and here's another :)

Where I was going wrong?


I had over specified the motors, then needed over specified Electronic Speed Controls (ESCs) and also looking down the wrong path for the ESCs.

It's so easy to go down the wrong path, I was so locked into checking robotic websites and component sites that I had neglected radio controlled hobbyists.  These guys need electric motors with ESCs and there's bucket loads of affordable offerings!!!
10 or 12A motors be fine! Then ESC cost only $12 each.  Even then a 30A ESC cost < $20 each.  Oh brilliant!

I'm so happy!!!  I can get an airframe (still need to decide), I know I have a solution for the motors and yes I can get affordable ESCs, what a result of a day!

One more question:  How to interface the ESC to the Gadgeteer Mainboard?

Monday, 21 January 2013

PC setting up

Good news, I've placed the order with Love Electronics for the Argon R1, a bunch of sensors and some other tiddly bits to get myself going!  Happy days :)

Time for a bit of action, let's get the computer set up.

I've not coded for about 3 years.  I do miss it a bit so it'll be lovely to get back into the swing of it again.  

Time to install my sweet heart Visual Studio.  Simply the best development platform I've ever used!

It's just amazing Microsoft have a free version called "Express", well done! Yes a thank you to Microsoft is needed otherwise for this project I'd have to shell out £500 for Visual Studio and other (optional) £300 for the MSDN.  

FYI, (start playing the violin) back in 1999 I paid £80 for a student licence of Visual Studio version 6, that was a lot of money/pints for a student to give up :)

VS Express C# installed, tick.  What next?

Well as I discovered there's two further parts you need from Mircrosoft: the .Net MicroFrame SDK and the Gadgeteer Core.  Silly monkey forgot to install the Gadgeteer Core :)

Next is the SDKs from the manufacturers for their electronics.  I installed them from Love Electronics', GHI and Seeed, why not the others might be useful one day!

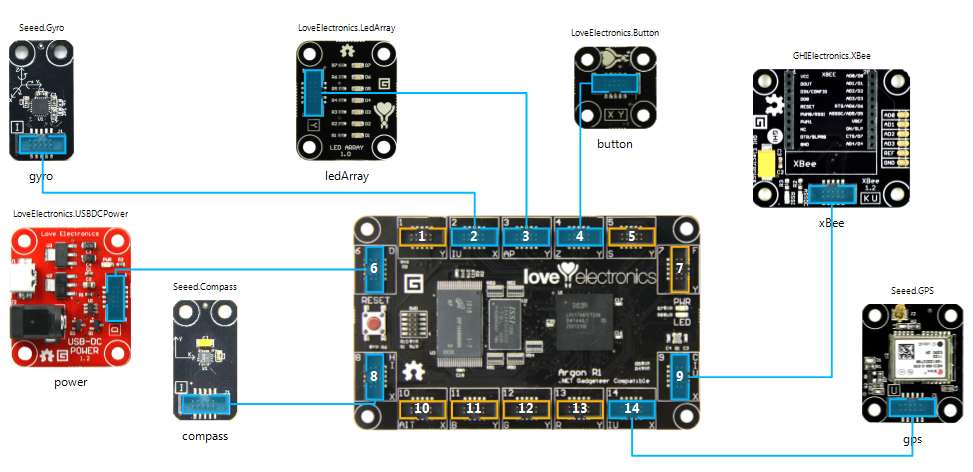
Easy evening!  Even had a bit of time for some fun Gadget layout :)


Arduino ... I've learned you could save me!

Ummmm, I think I'm mistaken about the Arduino system ... learning lots :)

More clicking about I see you can develop for it, excellent!

Arduino programs in C rather than an object orientated language so I'm still better going with the Gadgeteer board ... really a no-braining, C or C#!!!!

This complicated autopilot system will be much easier in C# however a few ideas are starting to hatch!

Perhaps, I can use the Arduino system for connecting all the sensors to?  Perhaps as a sensor pre-processing board?  Worth thinking about :)